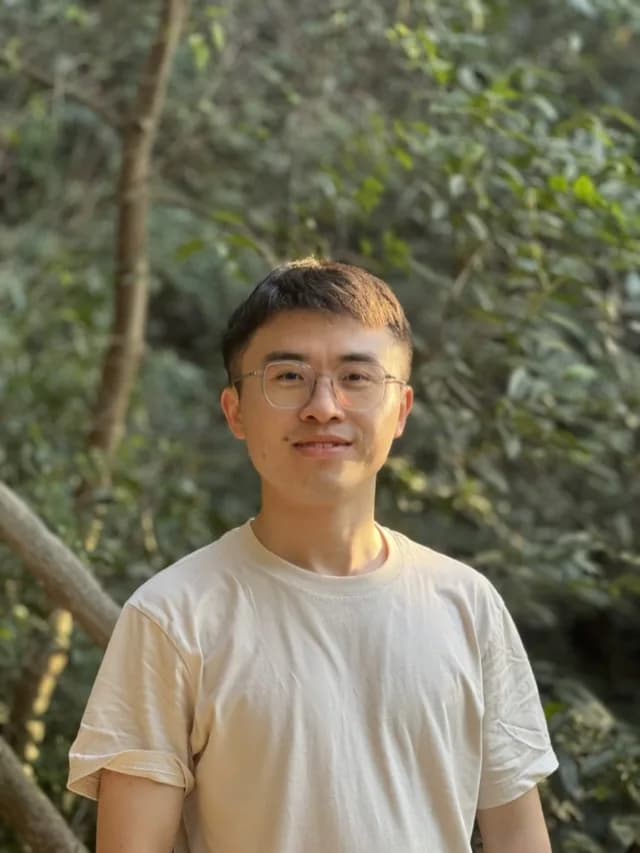
Hi, I am
Xinlong Li
Embedded Software Engineer / Robot Motion Control
Specializing in robot motion control, robotic arm development, and real-time embedded systems. Committed to seamlessly integrating control algorithms with hardware for high-precision, highly reliable automation solutions.
- C/C++
- ROS/ROS2
- Kinematics/Dynamics
- STM32/ARM
- RTOS
- PID/MPC Control
Featured Blog
View All →Featured Projects
View All →Real-Time Embedded Motor Controller
An STM32-based real-time controller implementing closed-loop motor control with deterministic scheduling and diagnostics.
- #STM32
- #FreeRTOS
- #FOC
- #Embedded
Mobile Robot Navigation and Localization
A navigation stack that combines LiDAR SLAM and visual odometry for robust mapping, localization, and autonomous path execution.
- #ROS2
- #SLAM
- #Navigation
- #Localization